By: Jose Alcantar, Electronics and Controls Engineer
HC-SR04 Experiment
Data Sheet Values:
Max Range: 4m
Min range: 2cm
Measuring angle: 15 degrees
Purpose:
Testing the field of view on the HC-SR04 to find a suitable mounting position for the two ultrasonic sensors along the front of the rover.
Procedure:
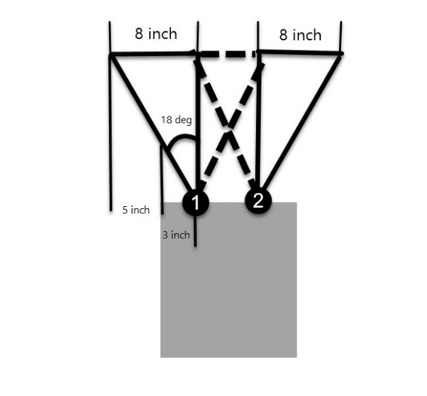
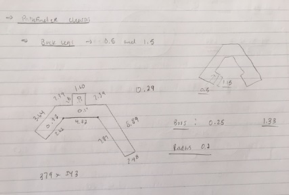
An object was placed in front of the ultrasonic sensor about 25 inches away; the position of the object was marked and moved in increments of 5 inches until the object was out of view. When the object was no longer detected the position was marked. The angle of the field of view was then calculated.
Results:
Based on the experiment, the angle of the field of view was found to be 18 degrees when measuring an object 25 inches away. The position of the sensors was determined by considering the clearance needed on each side of the rover. When considering the solar panels, the two ultrasonic sensors need to detect obstacles at least 5 inches to each side of the chassis. This will allow the pathfinder to avoid obstacles that may bump into the solar panels.
https://www.arxterra.com/wp-content/uploads/2016/11/rsz_picture1-2.png144144sabinasubedi/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngsabinasubedi2016-11-10 21:06:222018-03-13 22:01:17Ultrasonic Sensors – Field of View
Objective: The following experiments were used to determine if a DC motor can be used in place of a stepper motor by configuring it to be as precise as a stepper motor. Using DC motors will be beneficial to our design as we are trying to provide power.
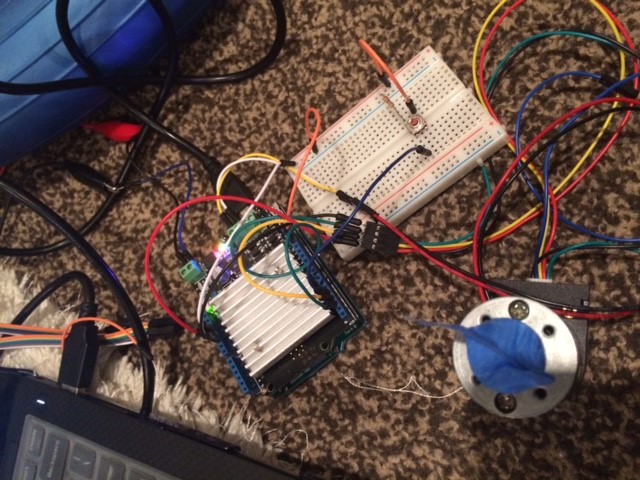
In the first experiment, the Arduino Uno was connected to an encoder—the signals the encoder provided was then analyzed as the shaft turned.
Parts Used:
Motor shield V2.0
DC motor with encoder
Push button
Breadboard
12V Power Supply
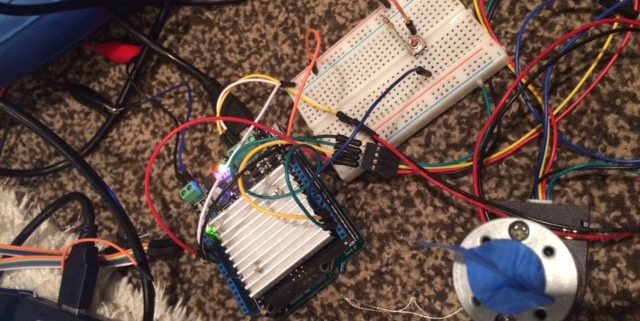
Figure 1: Breadboard Configuration
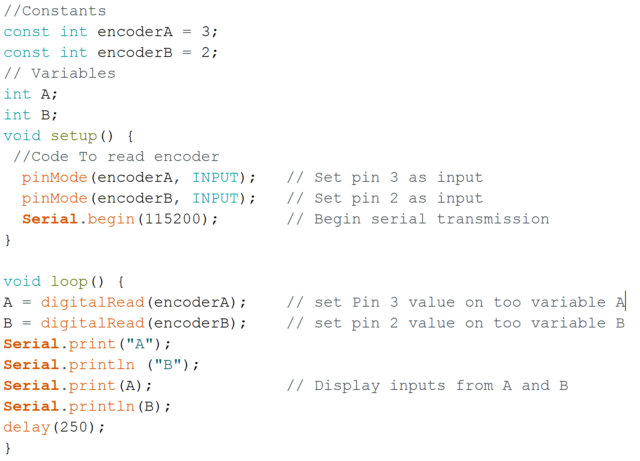
The following code was used:
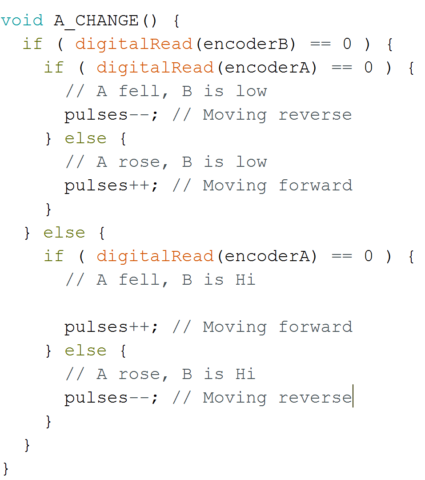
By taking a look at the serial motor I notice I was receiving zeros and once. The four different patterns received were 00, 01, 10, and 11 (this pattern repeated). Figure 1 explains the output of the serial motor where each output is offset by 90 degrees. The reason we have two outputs from encoder is to determine the direction of the motor. By analyzing the figure below, we can come up with a true table for direction.
Figure 1: Output of Serial Motor
If A goes from 0 to 1
B=1
Reverse
B=0
Forward
If A goes from 1 to 0
B=1
Forward
B=0
Reverse
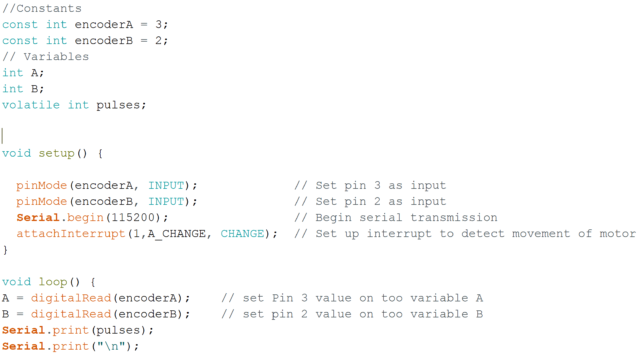
In order to track a pulse each time it occurs, we need to have an interrupt in our code so that we do not miss it. Every time a pulse occurs means that the motor has moved certain degrees. To find the ratio between pulses and degrees, I will measure the number of pulses for 1 rotation using the following code. Without adding power to the motor all that is required is to manually rotate the shaft 360 degrees.
A value of 2071 is what I tested for a full rotation. I divided 2071 by 360 and got 5.75. About 6 pulses will rotate the motor 1 degree and this concept is what I will used to control the motor with precision. If I will I like to move 2 degrees to the left or 2 degrees to the right, then 12 pulses are needed. Once 12 pulses have been received then the motor needs to stop. The next experiment will focus on being able to stop the motor after a full circle.
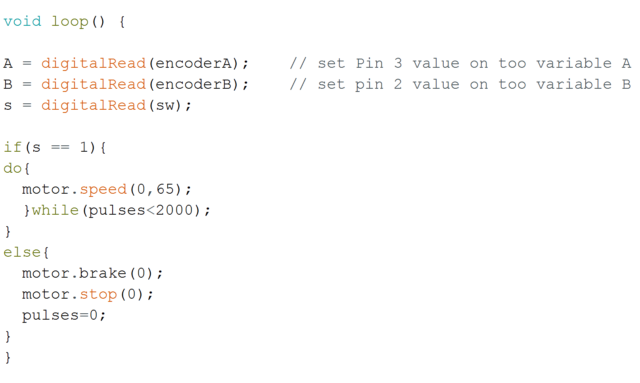
The following code was used to control the motor. A switch button is used to let the Arduino know when it should rotate. Pressing the button causes the motor to rotates and stops once 2040 pulse have been reach. Due to the fact that the motor is too fast, a perfect rotation cannot be done. A motor with slower rpm but strong torque could potentially respond better. In addition, a gear motor will be more acceptable because we can relate a 360 to 1 gear ratio as 1 degree for every rotation. In the solar panel design, a maximum gear ratio of 50 to 1 is what we can attain. A DC motor could not be used in our project. A stepper motor has been determined as the only option available due to time and gear ratio availability.
https://www.arxterra.com/wp-content/uploads/2016/11/400d.jpg480640Inna Echual/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngInna Echual2016-11-09 22:17:202016-11-09 22:36:02Fall 2016 Solar Panels: DC Motor with Encoder Experiment
The team received the PDR debrief from meeting with the customer and the president. A concern of theirs was that our mission profile presented during the PDR (1) was not updated as the Chassis group in the Thursday class had changed their course to an area with a stronger WiFi signal and (2) was representative more of the Chassis group’s mission profile instead of ours.
Because of the two reasons, the team then developed a new mission profile which will clarify the confusion present in the current one.
Previous Mission Profile
The project will be demonstrated by charging the pathfinder’s battery using solar panels in order to completing the course defined by the Spring 2016 AdBot rover, as shown in Figure 1. This course is on the California State University, Long Beach campus, specifically in front of the University Student Union building and will be conducted at night for better operation of the LiDAR sensor.
Figure 1: Spring 2016 AdBot Rover Route
Updated Mission Profile
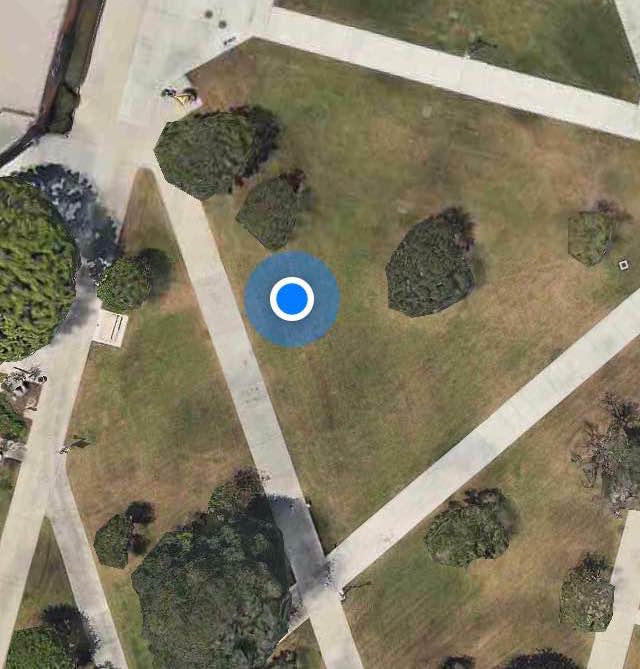
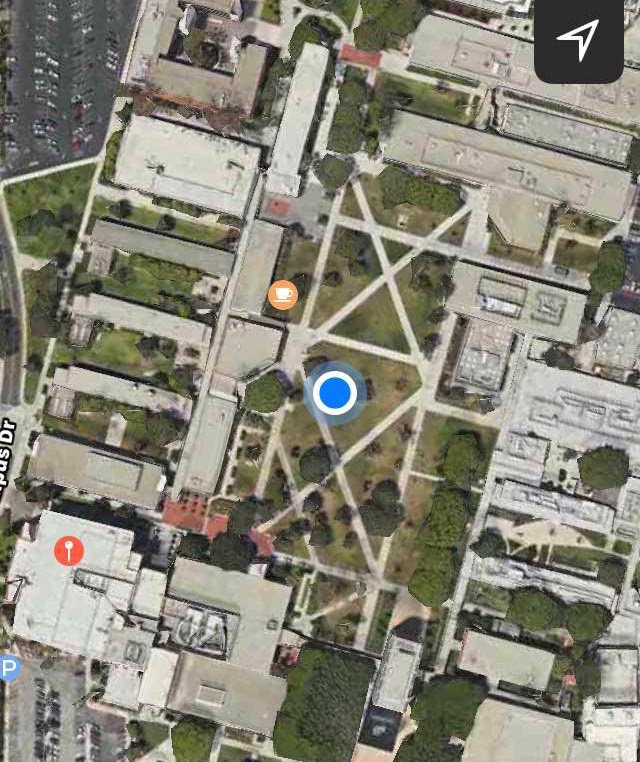
The project will be demonstrated by parking the Pathfinder in the Central Quad on California State University, Long Beach located at 33°46’40.7″N 118°06’48.9″W. In addition to the location near the defined travel course, the parking spot was chosen as it had low traffic and free of shading. The parking spot is indicated in Figure 2.
Edited and Approved By Inna Echual (Project Manager)
Folding Mechanisms Considered
Objective: One of the most important components of our project is to define the folding mechanism that will allow us to achieve the cocooning requirement. This study will showcase the mechanisms we considered and which of the ones research was chosen.
Rack and Pinion
Video 1: Rack and Pinion Folding Mechanism
This idea was brought up through a YouTube search on “folding mechanisms,” resulting in the rack and pinion method in the video above. The folding is accomplished by sliding a rack back and forth and spinning a spur gear placed at the hinges of the panels. This configuration was created to fold t-shirts but I found this video to be very helpful.
For doing this method, the rack would have to be suspended from underneath the panel because doing a two-layered panel configuration like the video would be unfeasible as it would result in more materials, adding cost and weight. Taking those factors into account, it was additionally determined that is method is not the best for folding our panels since having the rack be suspended underneath could prevent the side panels from going -15° (for example) when the panels articulate to track the sun.
However, this video inspired us to consider attaching a gear to the pin of a hinge and to consider a gearing mechanism to do the folding of the panels.
Linear Actuator
Video 2: Linear Actuator Folding Mechanism
This method of using a linear actuator was both found by doing the same YouTube search and as suggested by Professor Hill. Though the linear actuator would provide enough force to push open our panels despite its weight, we had many concerns:
An obvious placement of the actuator would be on the stationary front side panel and on the side closest to the base (see Figure 1). This placement would cause two problems: (a) we would be losing valuable real estate for putting our solar cells, space that we need to achieve power generation for charging the battery. And (b) putting the actuator on the top will prevent our back side panel from completely closing onto the back front panel, which also brings up the problem when folding the two onto the base for the cocooning.
To fix the problems brought up in (1) above, we considered placing two pads on the side of the front panel furthest from the base panel (see Figure 2). Our problem with this placement is that we assumed putting pads there would dissatisfy with the Level 1 Requirement of having the panels be identical to that of the Opportunity and Spirit rovers. The placement there would also be not ideal as since the actuator is on the other side of the side panel, it could interfere with the rover’s overall center of mass.
We also considered placing the actuator underneath the panels but we had difficult time finding a mechanical configuration to encompass the 0° to 180° range of the panel folding.
Therefore, we determined that this method was not the best and we continued to research further on folding mechanisms.
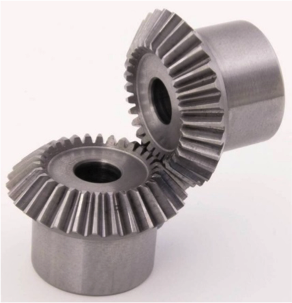
Bevel Gear
Figure 3: Bevel Gear
Through we are not considering rack and pinion method for folding, we were inspired by the gear to incorporate a bevel gear into the mechanism to lift the panels into position. One bevel gear would be fixed to a rod extending from piano hinge and that pin of the hinge will be welded to one side of the hinge on the panel that needs to be lifted.
The main concern is the panel could not be kept at a specified angle and the motors would have to be constantly turned on to hold the panel at that angle. After the Iterative design process and additional research, the worm gear was considered for its self-locking feature.
Worm Gear
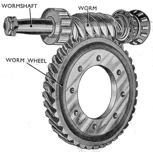
Figure 4: Worm Gear
The worm gears are considered because of power transfer due to the effectiveness of the two gears meshing. One appealing feature is that they are self-locking, meaning that the gear cannot drive the worm. For example, when the weight of the panels exerts torque, the motor is not affected; if the panels are going from 90° to 180° there won’t be load exerting torque on the stepper motor. Another feature is that they occupy less space which would declutter the design and reduce overall mass.
The most important advantage is that they are known for being used for speed reduction and increasing torque. This will be extremely helpful when doing a lifting action for our sun articulation.
Mounting the Stepper Motor
A custom bracket shall be designed to allow to mount the stepper motor low to the ground.
Torque
Take the right back panel for example:
Weight of panel on SolidWorks using 6061-T6 Aluminum = 165 grams
Distance
For safe measure a weight of 250 grams will be used.
So, a motor with a torque of 23 oz.in or higher will in theory be able to lift the right pack panel.
Gear Ratio
As stated earlier, one of the advantages of worm gear is having higher gear ratios. For this example, a 30:1 gear ratio will be examined.
Motor – NEMA 17-size hybrid stepping motor with a torque of 44 oz.in
Motor Torque x gear ratio = torque at the hinge
This is more than enough to be able to lift the panels.
Figure 5: Lever Arm from Axis of Rotation
https://www.arxterra.com/wp-content/uploads/2016/10/worm.png152153Inna Echual/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngInna Echual2016-10-25 22:21:072016-12-06 16:31:05Fall 2016 Solar Panels: Folding Mechanism Trade-Off Study
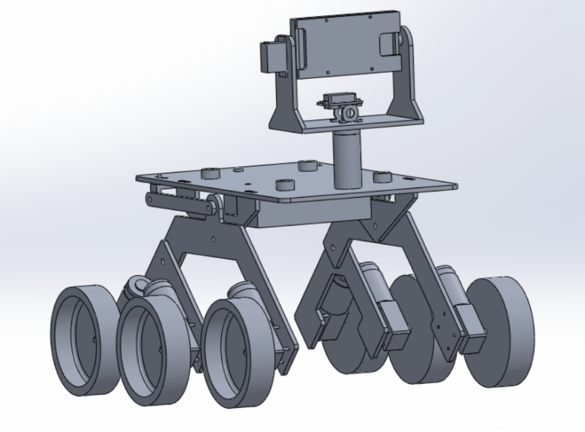
The mechanical design of the Pathfinder utilizes many parts and sub-assemblies in order to achieve all the requirements associated with the overall design. In order to achieve the level 1 requirement of being able to successfully traverse a pre-determined course on campus it was necessary to utilize a proper suspension system. It was also necessary to completely rebuild the pan and tilt smart phone holder in order to fit a Samsung Galaxy S7 edge. The suspension design utilizes a rocker bogie suspension system very similar to the one used on the Spirit rover. Below is a description of the overall mechanical design including all of its assemblies and sub-assemblies.
Initial Design Process
The Spring 2016 Pathfinder was used as a base reference in order to come up with a usable overall design. Each part was measured and then modeled in solidworks in order to come up with working parts and assemblies. The pictures above shows some sketches of the various parts that needed to be measured, modified and then modeled. It was necessary to change the overall geometry of the suspension and platform in order to achieve some of our desired design outcomes such as wheel clearance and lower center of gravity.
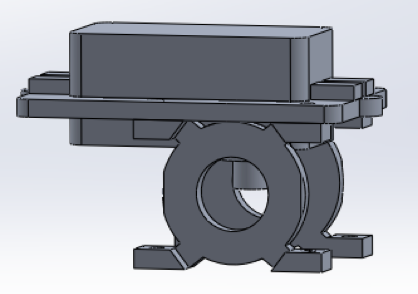
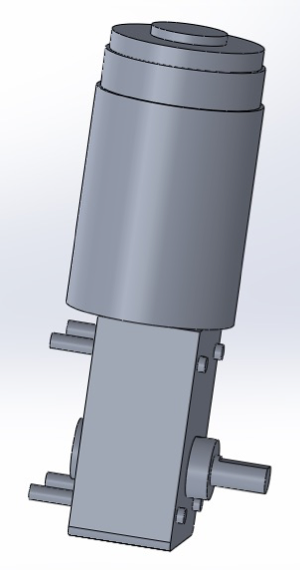
The above pictures are models of the base servo mechanism and the actual motors that are used. It was necessary to properly model these in solidworks in order to get a more accurate overall model of the pathfinder. The base servo mechanism mounts the servo that controls the pan motion of the smart phone holder. Adding the motors gives an accurate measurement of the width of the Pathfinder.
Overall Design
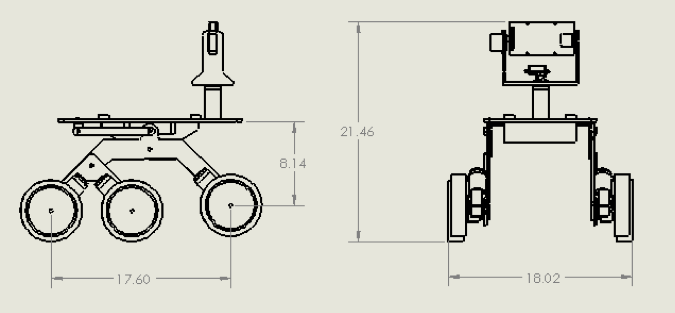
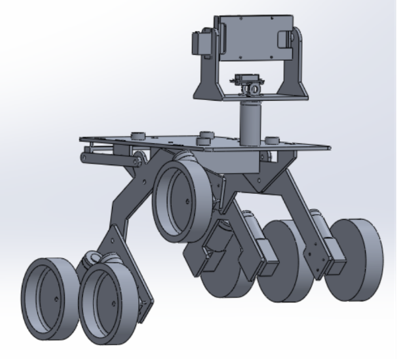
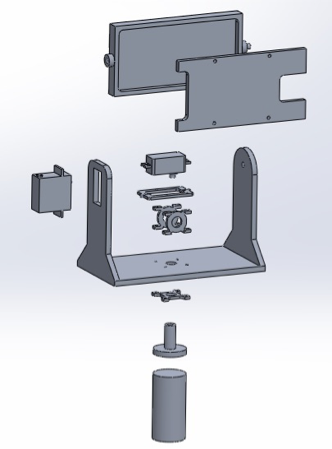
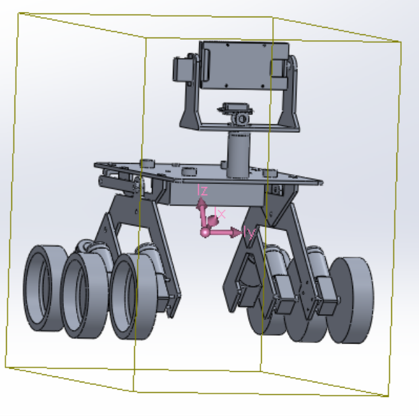
The above pictures show a 2-D drawing as well as a 3-D exploded view of the Pathfinder design. The overall dimensions of the design can be seen below.
Height: 21.6 inches
Width: 18.02 inches
Length: 23.60 inches
Floor to Top panel: 11.14 inches
The overall design can be broken into two basic sub-assemblies. These include the rocker bogie suspension system and the pan/tilt smart phone holder. Descriptions of these sub-assemblies can be seen in the next sections.
Rocker Bogie Suspension System
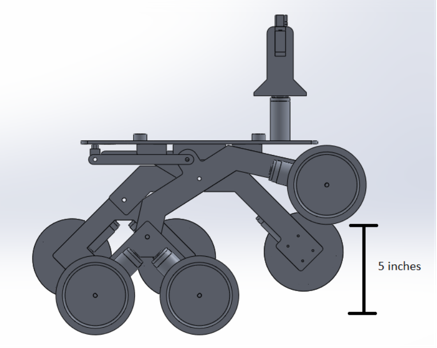
The rocker bogie suspension system that was utilized in our design is very similar to the one used on the Mars Spirit rover. This suspension system is good for uneven surfaces and requires no springs or dampening mechanisms. Each wheel can move up and down independent of one another. Another benefit of this suspension system is that the main body stays straight and upright while going up of down steep surfaces. This creates good weight distribution and helps prevent the Pathfinder from tipping over. The overall wheel clearance of the suspension system was designed to be 5 inches due to the fact that it will need to go upstairs that are about 5 inches tall. The diameter of the wheels is 6 inches, therefore the height of the Pathfinder from the ground to the bottom of the base platform is 11.14 inches.
Pan/Tilt Smartphone Holder
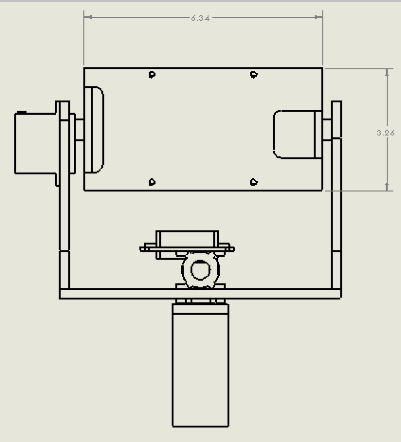
The pan/tilt smartphone holder is designed to hold a Samsung Galaxy S7 edge. The dimensions of the phone are 5.94 x 2.86 x 0.30 in. The holder case was designed to have the following dimensions: 6.34 x 3.26 x 0.7 in. The thickness of the case will be 0.2 inches which will allow for the phone to be fully covered. The front cover plate was designed to have cutouts in the appropriate locations. The cutouts can be seen in the picture above. These cutouts are for the camera and for the antennas in the phone. It is necessary that these do not get covered in order to obtain good signal strength. The pan/tilt servos will be able to move 180 degrees in both directions.
Lower Center of Mass
The goal of the design was to get the center of mass as low as possible. The picture above shows the center of mass in purple. The previous design had a center of mass the was above the main pivot point of the rocker bogie front arm. The design focused on lowering the center of mass below the pivot point. This was achieved by redesigning the top platform and lowing it an inch. Lowering it an inch meant that the clearance would also be 1 inch smaller which was a problem. This was solved by making the rocker bogie arms one inch longer. The electrical box and battery will also be mounted on the bottom too which helps make the center of mass lower.
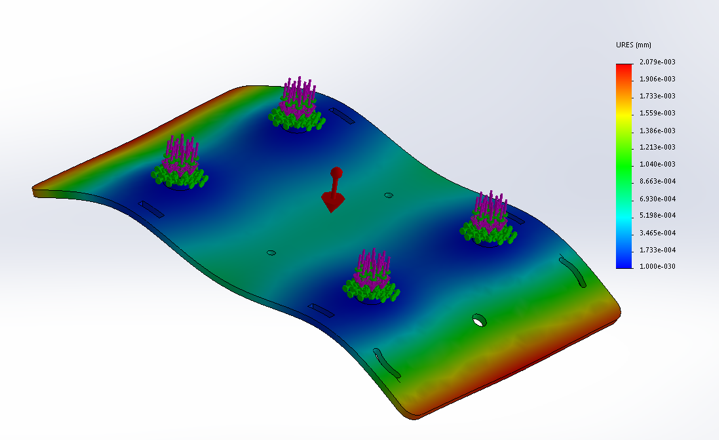
Stress Test (Base platform only)
The top panel was analyzed to see how it would react to an outside force being applied to it. The top panel will carry the majority of the load which includes the Solar Panels, the Pan/Tilt Smartphone Holder, the Batteries and the Electronics. The above photo is an exaggerated simulation on how the panel may deform under certain stresses.
Solar Panel Interconnection
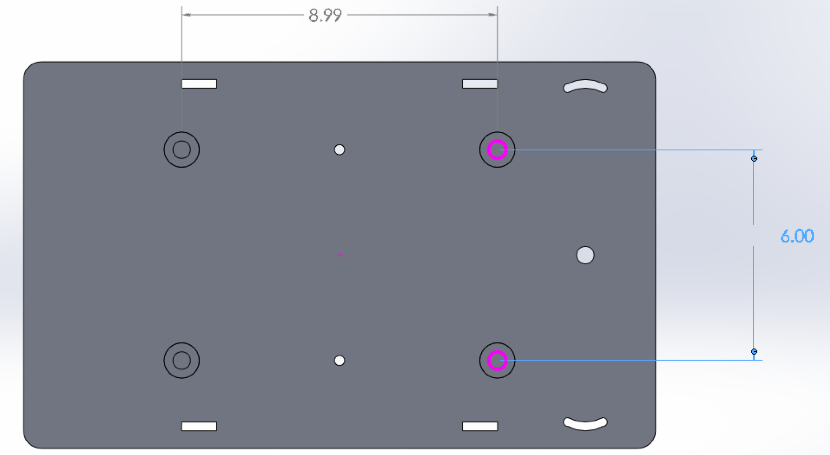
It will be necessary to properly interconnect the chassis to the solar panel assembly. The picture above shows the interconnection mounting points and the dimensions. 4 connection points will be used for optimal stability. These connection points will be raised pads with holes drilled through them. The solar panel assembly will then align with the holes and quick release pins win hold them in place. This will allow for quick removal of the panels.
Objective: Motors we need to select must be able to hold the panel at different angles with precision with maximum 12 volts and 2 amps to fulfill the sun tracking requirement. In order to do this, a minimum torque of 50 oz/in is required based on our calculations.
Stepper Motor:
Need to consider the positioning resolution because the number of steps per revolution range from 4 to 400.
Note: Resolution is expressed in degrees. Example- 1.8⁰ is 1.8360= 200 step/rev motor
Higher resolution torque effects the speed and torque by decreasing both as resolution increase
Gearing can help to increase resolution without having to loose torque
In addition, torque can be increased, but the tradeoff will be speed
Pros
Precise positioning
Low Speed Torque
Cons
Low Efficiency- draw the most current when not doing any work
Less Torque at high speed
No feedback- Limit switches or detectors typically required for safety and establishing a reference position
Require a stepper controller to energize
Cost more
Four inputs
DC Motor:
Pros
Cheap
Efficient
Can be controlled using an H-Bridge circuit
Only need two inputs
Cons
Can’t be used for precision
Noise is introduced if not brushless
Brushless DC motors- require a separate controller, ESC
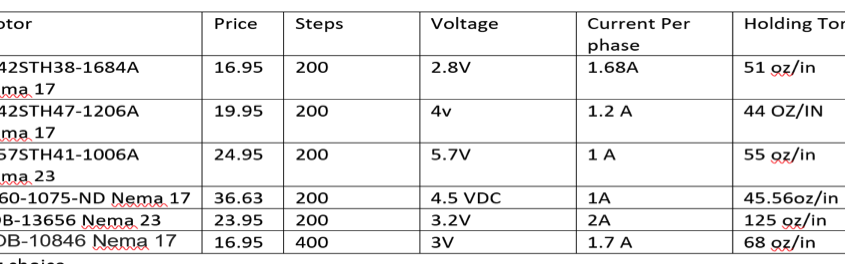
Based on the two key differences on these two motors, we concluded that we will need to use 2 stepper motors to control the sun tracking on the solar panels. Precision is needed and the stepper motor is the only motor that can be controlled to fulfill that precision requirement. In addition, a constant-holding torque is required to hold the panels and the stepper motors are able to provide this. Since the other panels do not require any precision or holding torque, DC motors are more acceptable to be used than stepper motors. The following table shown in Figure 1 will show the motors that I compared and based on my needs I picked one of the 6.
Figure 1: Stepper Motor Comparisons
Final Decision:
The final decision for making the sun tracking possible are the two stepper motors SY57STH41-1006A. They are my choice because it draws only 1 amp and has a holding torque of 55 oz/in, which is required to articulate the panels efficiently.
https://www.arxterra.com/wp-content/uploads/2016/10/Untitled2-e1476808741879.png163600Inna Echual/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngInna Echual2016-10-18 16:59:272016-12-06 16:32:47Fall 2016 Solar Panels: Motor Trade-Off Study
A set of different types of sensors were considered for detecting no load conditions on the Pathfinder, these include:
Current Sensors: These type of sensors allow the user to monitor the current draw on each of the motors.
Flex Sensors: This type of sensor measures the deflection caused by bending of the sensor.
Pressure Sensor: This sensor typically measures the pressure of gases.
Micro switch: This type is a switch that is actuated by physical force
Each of these types of sensors presented both pros and cons when deciding on which to implement on the pathfinder. Starting with the flex sensor, the proposed idea was that as the pathfinder was traveling the suspension system would move and bend as the rover drove along. As soon as one of the wheels came off the ground, the flex sensor would detect this and shut off power to the motor. The biggest problem in implementing this idea is that the rocker bogie system does not bend while it is driving. This makes the sensor in the field unreliable.
The idea with the pressure sensor was that the pressure in the tires would be measured. This would be beneficial if the rover had air-filled tires, which would detect when the tires would come off the ground. With the new design of the rover, this would become an issue due to the use of foam-filled tires.
Similar with the flex sensor, the micro switch would detect any force on the sensor if the suspension lifted a tire off the ground. The problem with this is with the design of the rover, there would be no suitable areas to mount the sensor on the pathfinder.
The best option for the rover were the current sensors. Due to the current draw of each of the motors, a current sensor can be wired in series with the motor to measure the current. Of the different types of current sensors, two were selected as the best options. The two options were the use of a 0.51Ω current sensing resistor and the Adafruit INA219.
When considering the two options the main differentiator between the two was the cost. The Adafruit INA219 has a total cost of $9.95 and multiplying by six (one for each motor) the total comes out to about $60. The shunt resistor has a cost of about .56 cents each, the total coming out to being about $3.50. Another benefit of using the shunt resistor is the fact that the motor shield being used has a pin output specifically for the use of current sensing resistors. Ultimately, the shunt resistor appears to be the best option due to the cost, the easy implementation, and least use of pins.
https://www.arxterra.com/wp-content/uploads/2016/10/rsz_14794160_1260038724059037_460867603_n.jpg144144sabinasubedi/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngsabinasubedi2016-10-06 20:37:462018-03-13 22:01:18Sensors for no load condition Trade-Off Study
By: Nick Lukin (Manufacturing and Design Engineer)
Two motor driver shields were taken into consideration for the Pathfinder Project, the Pololu VNH 5019 and the Adafruit V2.3. Each shield had its own pros and cons and there were a variety of factors that needed to be taken into consideration during the evaluation process. The figure below shows a comparison of both boards.
Table 1: Comparison of Polulu VNH 5019 and the Adafruit V2.3
Continuous and Peak current capabilities of each driver shield were evaluated in order to find out what each shield could handle. The motors that we chose to use are 12 volt DC worm gear motors. These motors have a no load current of 0.96 A, a full load current of 1.8 A, and a stall current of 4.8 A. The Pololu VNH 5019 can handle the loads of the motors while the Adafruit V2.3 cannot. The next factor considered was the number of pins used for communication between the Arduino Leonardo and each shield. The Pololu VNH 5019 requires a minimum of 6 pins to control 2 motors. In order to separately control each motor (6 motors) a total of 18 i/o pins would be needed and the Leonardo only has 20 i/o pins total. This creates an issue because pins will also be used to control servos and take in sensor inputs. The Adafruit V2.3 uses i2c for communication and therefore will only require two pins from the Leonardo (SCL and SDA). The next factor taken into consideration was the additional features that each board offered. The Pololu VNH 5019 has built in current sensors that could be used to meet the requirement of stopping each motor under no load conditions while the Adafruit V2.3 has built in servo control that could be used for the pan and tilt mobile phone holder. Each shield has its pros and cons but ultimately we chose to go with the Pololu VNH 5019 because it can handle the load of the DC motors that we plan to use. It is necessary for us to keep the motors that are presently on the Pathfinder because they can handle the heavy weight of the chassis and solar panels. In order to solve the pin issue associated with the Pololu VNH 5019 we plan to use a MCP23017 – i2c input/output port expander. This port expander will give us an additional 16 pins. Our design will use 3 Pololu VHH 5019 motor shields stacked on each other to drive 6 motors. We will also be able to utilize the built in current sensors in order to stop our motors under no load conditions.
https://www.arxterra.com/wp-content/uploads/2016/10/rsz_1411-00.jpg144144sabinasubedi/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngsabinasubedi2016-10-04 21:12:562018-03-13 22:01:18Motor Shields Trade-Off Study
The WBS shows all the work that is to be completed by the Pathfinder – Chassis group. The WBS is arranged into three main sections or divisions – Mission Systems & Test, Electronics & Controls and Design & Manufacturing, where each section is a responsibility of the corresponding division member. The three sections are then divided into various groups, which include specific sets of tasks that are relevant to the group.
Figure 1: Work Breakdown Structure
Project Schedule
By Sabina Subedi (Project Manager)
Top Level Schedule
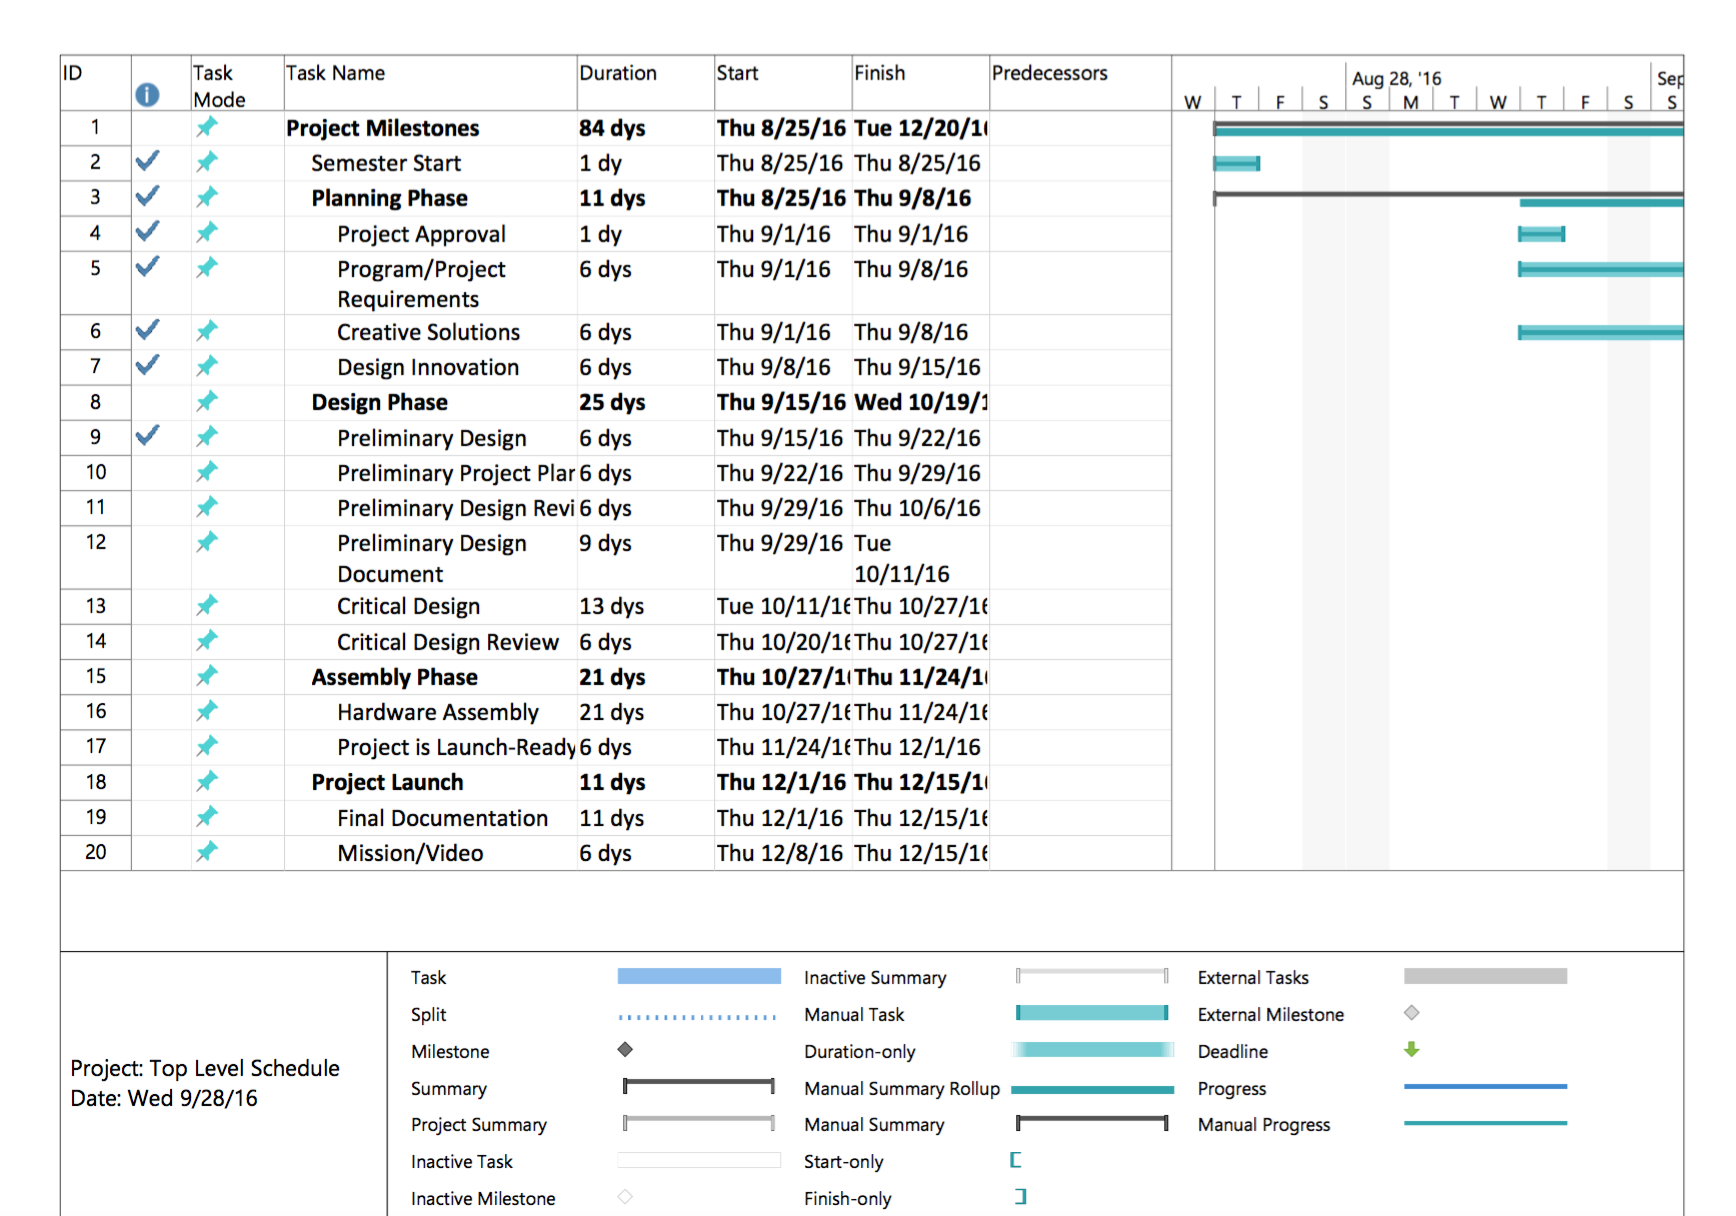
The top level schedule below was created using the generic schedule provided on the class website. This schedule consists of all tasks that are to be completed before the end of the semester, December 15th, 2016. The project milestones are broken down into four phases: Planning, Design, Assembly and Project Launch. The tasks within the different phases are then divided up by the divisions.
Figure 1: Top level schedule (Generic)
System/Subsystem level tasks
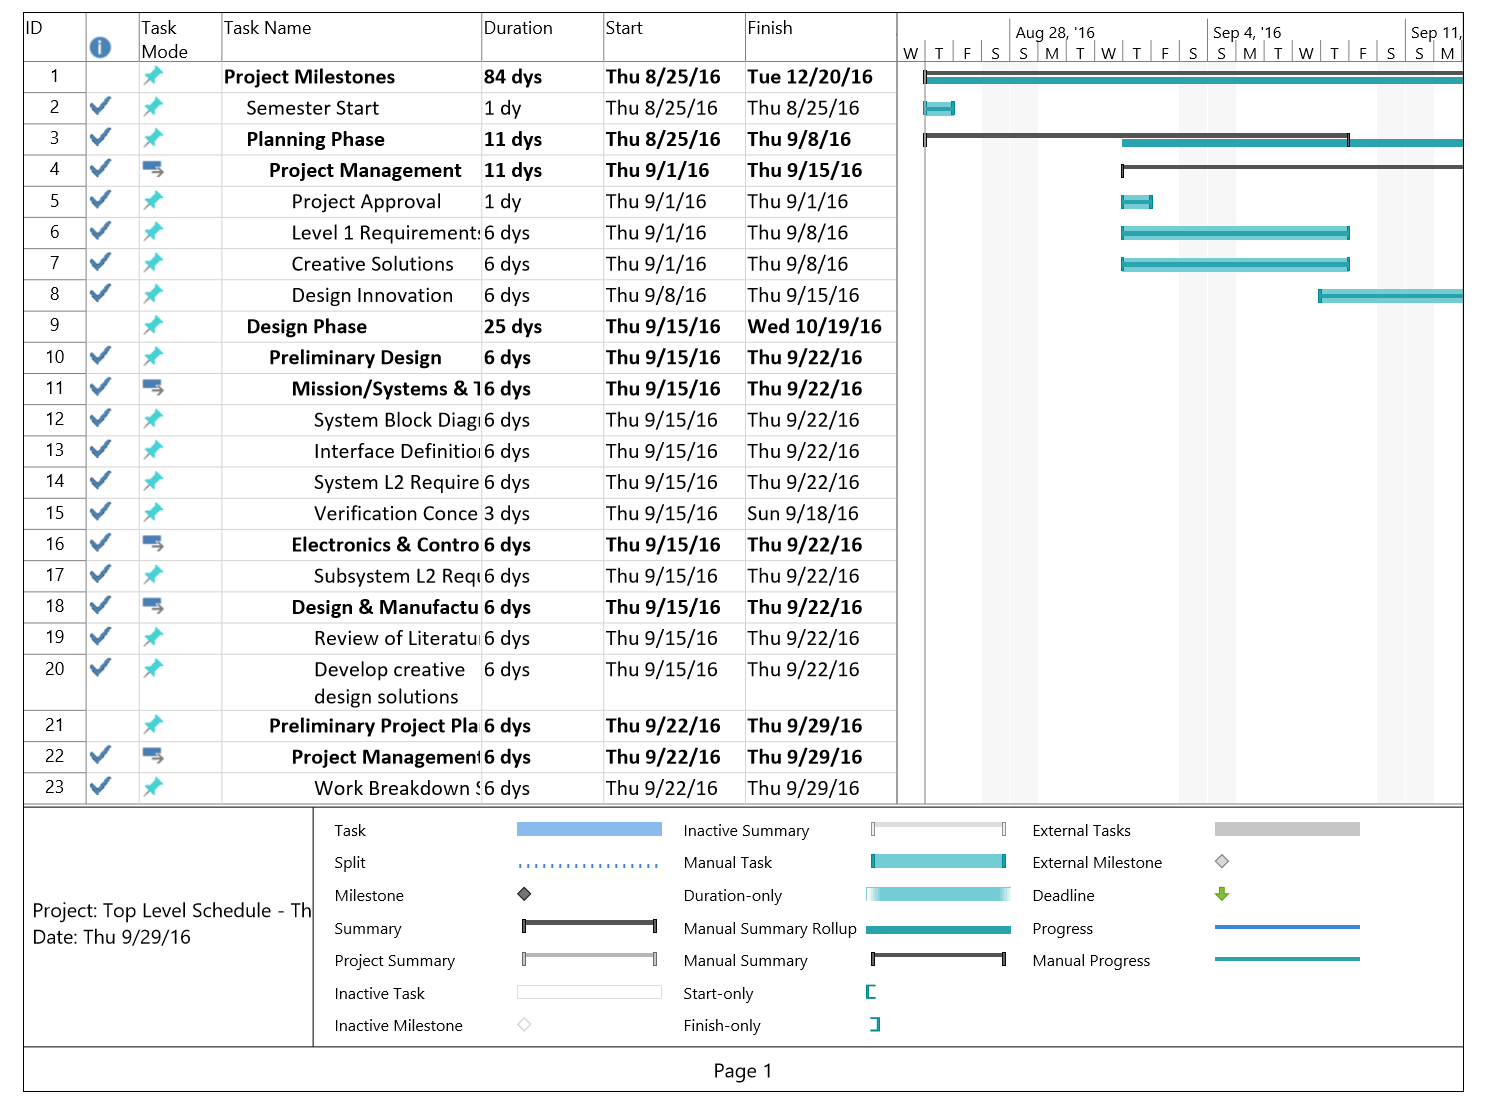
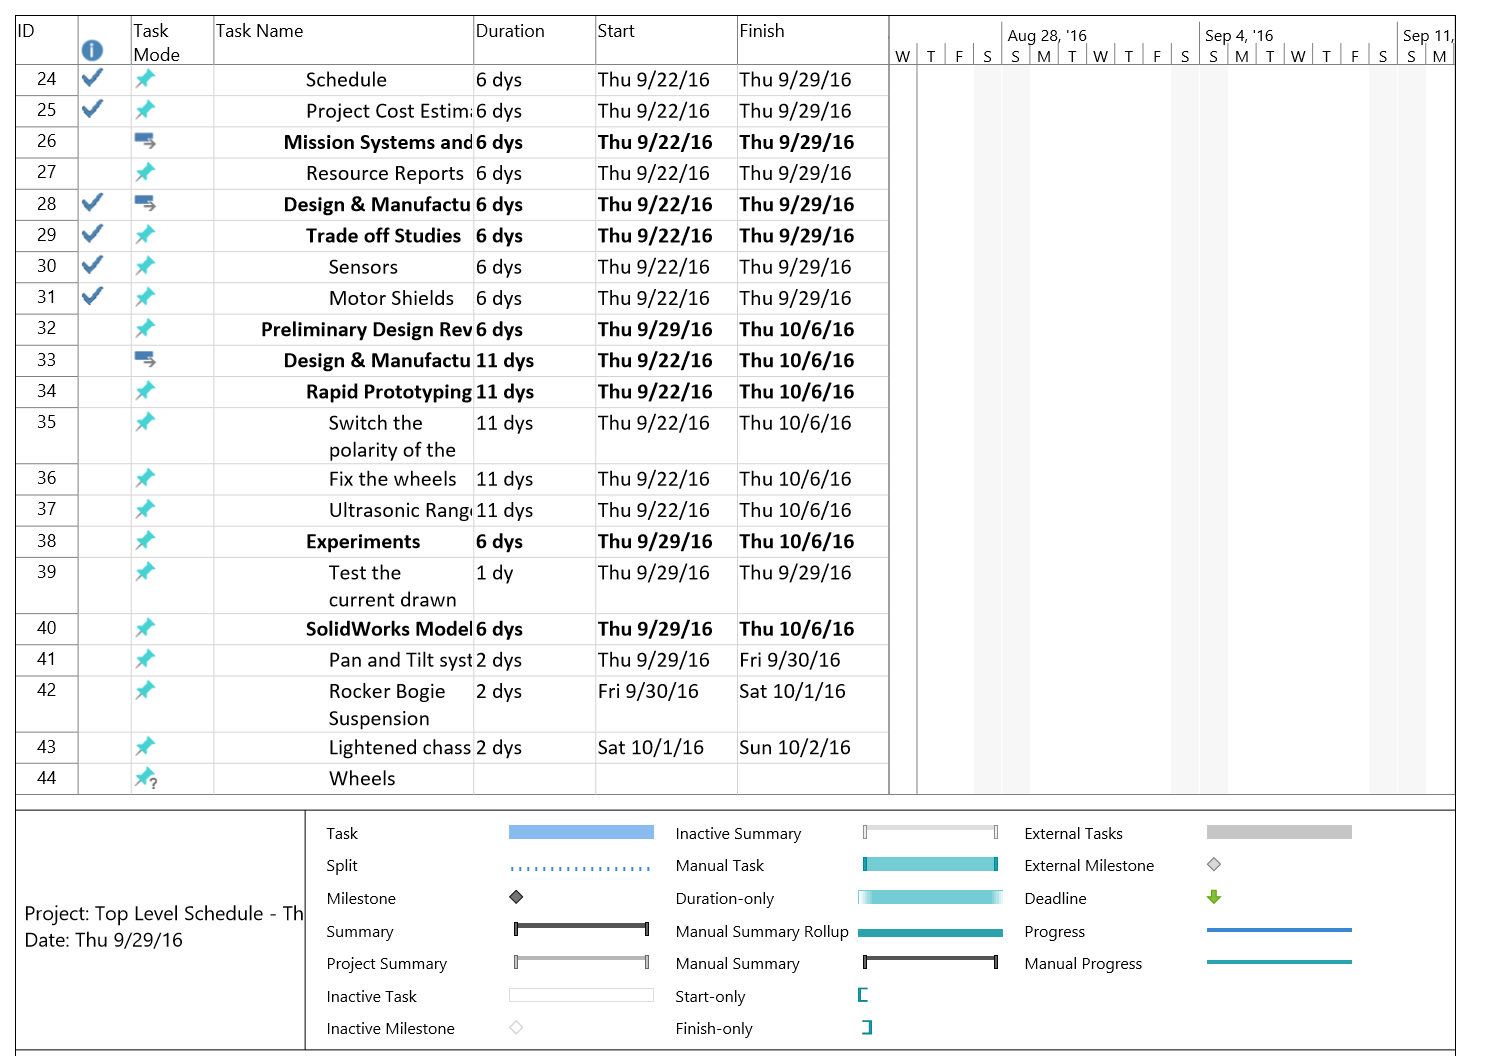
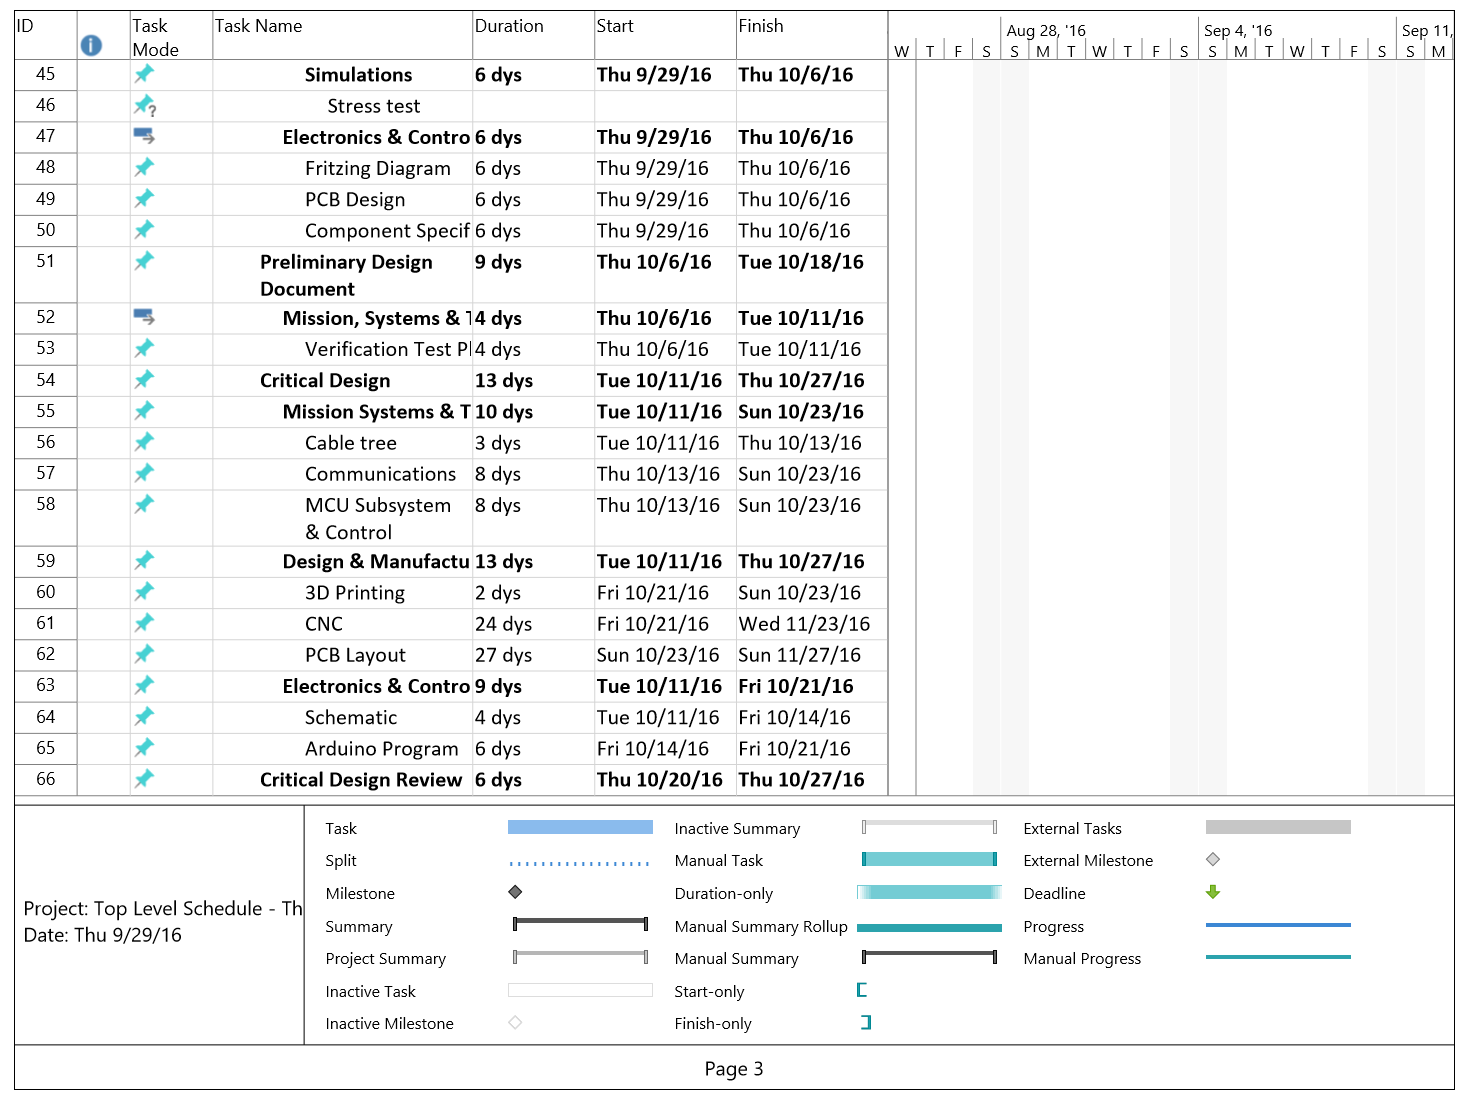
The generic top level schedule was then modified to include all system/Subsystem level tasks in accordance with the WBS above. All division members are assigned specific tasks that they are responsible for, per “Job Descriptions” document available on the class website. Main tasks then were broken down into sub-tasks, if applicable. All tasks include start and finish dates, as well as percent complete. Blue check mark denotes tasks that are 100% complete.
Figure 2: Schedule including System/Subsystem level tasks
Burn Down and Project Overview
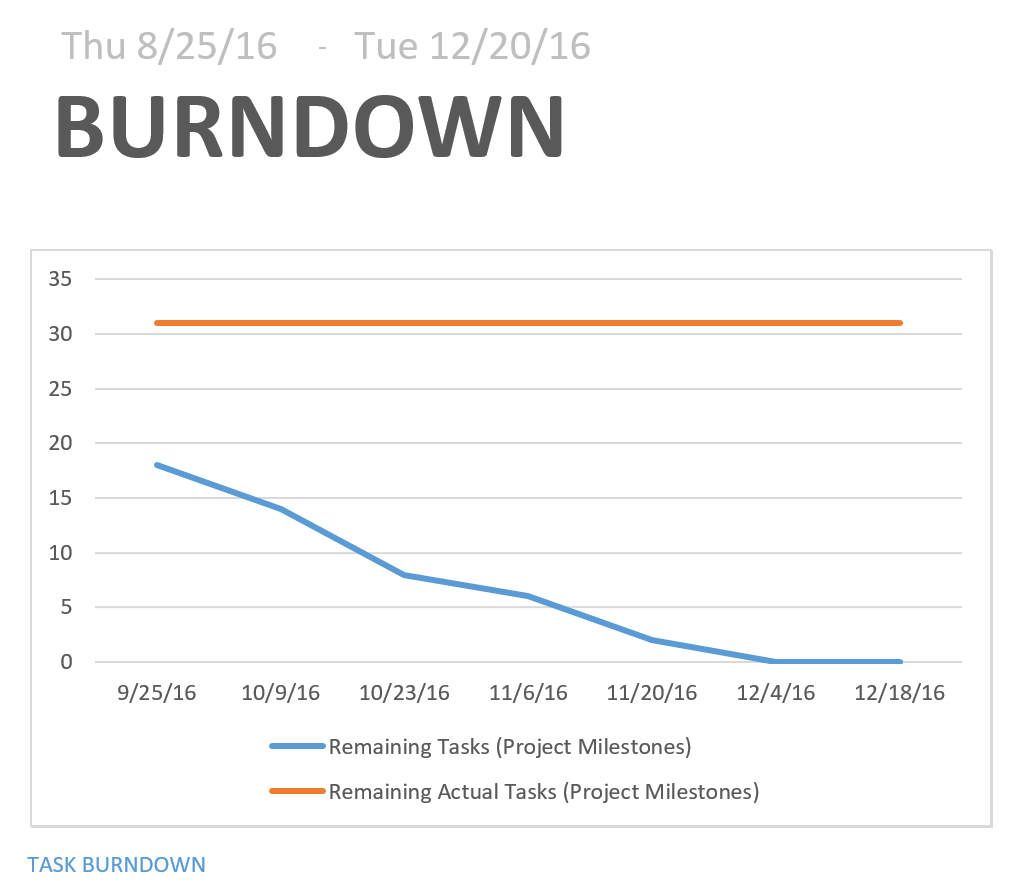
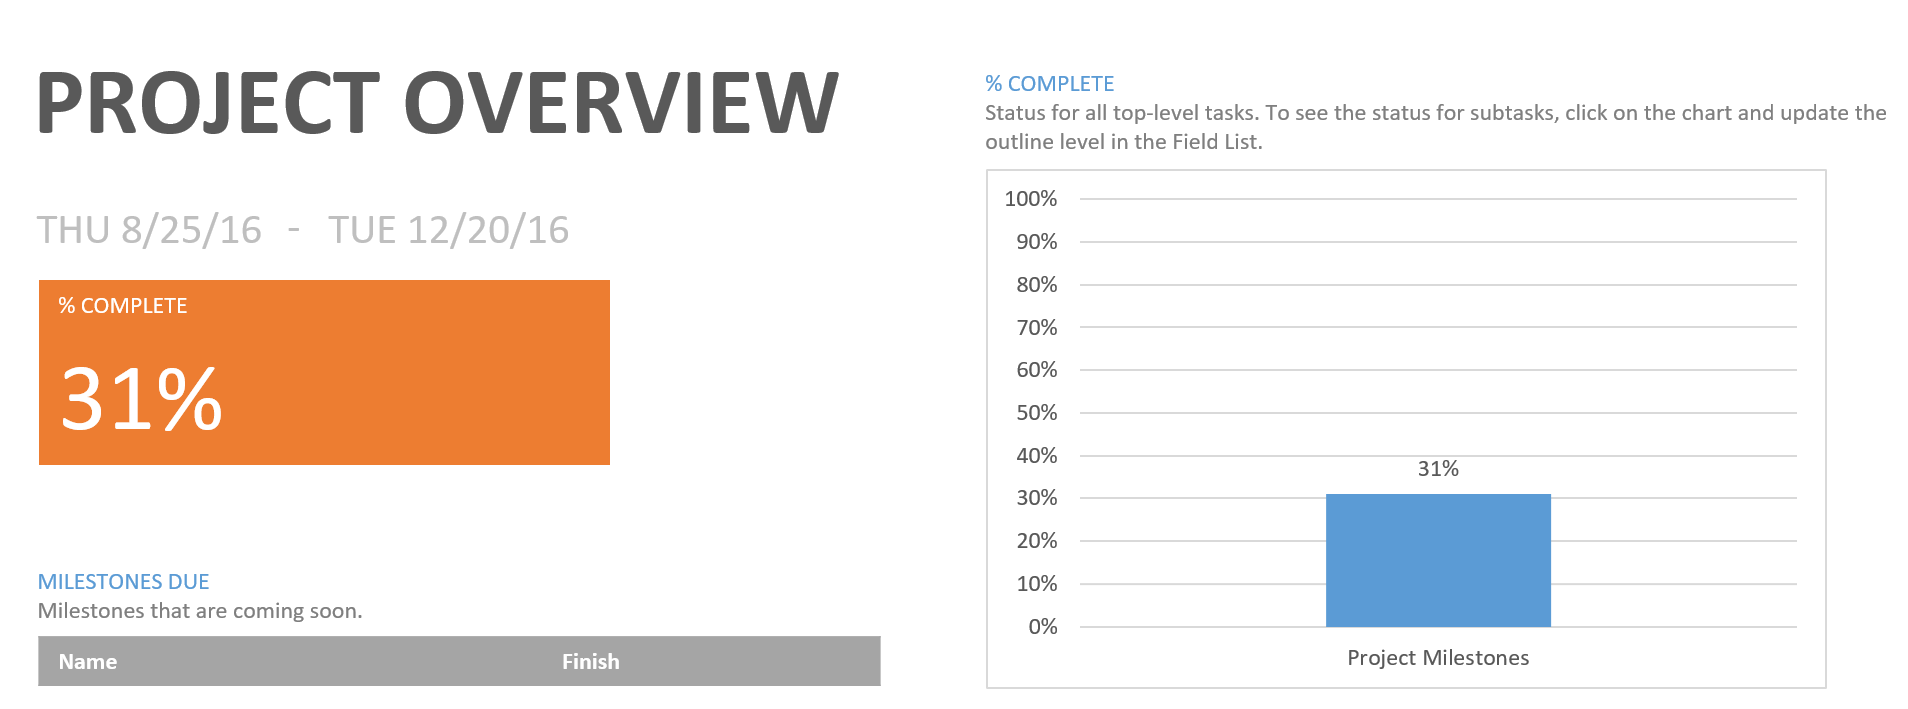
The burn down chart below shows how many tasks are completed and how many are left. The project overview graph shows the percent completed as of today, September 29th 2016.
Figure 3: Task burndown chart along with project overview graph
System Resource Report
By Adan Rodriguez (Mission Systems and Test Engineer)
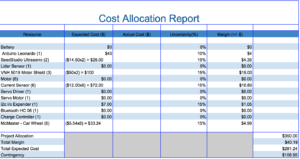
Cost Allocation Report
This cost report is a rough estimate of the expected cost of each component on the Pathfinder. Our expected prices for each item excluded tax and shipping price. Tax and shipping prices were included in the Uncertainty category. Some of the items were marked at $0 for expected price because the item was either already on the Pathfinder from previous semester or the item was given to the team. Since there is no budget requirement, the Project Allocation was determined by adding up the expected price of each item and choosing an amount slightly higher than the total expected price.
Figure 4: Cost Allocation Report
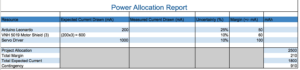
Power Allocation Report
This power report displays the expected current drawn by each component that will be drawing power from the battery. The team had trouble identifying the current that would be drawn by the VNH 5019 motor shields. For now we have used rough estimate of the current drawn by the VNH 5019 motor shield by using the same current rating of the Arduino Leonardo. The battery being used on the Pathfinder has a power rating of 10,000 mAh. We considered the 4 hour duration of the mission in order to come up with the Project Allocation value. We simply divided the power rating of the battery by 4 in order to come up with a Project Allocation of 2,500 mAh.
Figure 5: Power Allocation Report
Mass Allocation Report
This mass report is a rough estimate of the expected weight of each component on the Pathfinder. Some of the expected weight values are rough estimate because some of the item weight values were tough to find. Rough estimates were made relative to similar size of items. For example, the SeedStudio Ultrasonic sensors were estimated to weigh a fraction of the weight of the VNH 5019 motor shield because we had accurate weight values for the motor shields. The Mass Allocation Report will be updated once we actually weigh items with a scale. Since there is no weight requirement, the Project Allocation was determined by adding up the expect weight of each item and choosing an weight slightly higher than the total expected weight.
Figure 6: Mass Allocation Report
Project Cost Estimate
By Sabina Subedi (Project Manager)
The total expected cost is $281.24, based on the cost allocation provided above. The cost allocation report consists of rough approximations of the expected cost of each component. The components listed have not been purchased. Further trade-off studies are to be done before any purchases are made. Therefore, the total estimated cost is subject to change as the project progresses.
https://www.arxterra.com/wp-content/uploads/2016/09/rsz_top_level_schedule_-_thepathfinder.png144144sabinasubedi/wp-content/uploads/2013/04/Arxterra-Logo-340x156.pngsabinasubedi2016-09-30 00:25:542018-03-13 22:01:18Preliminary Project Plan
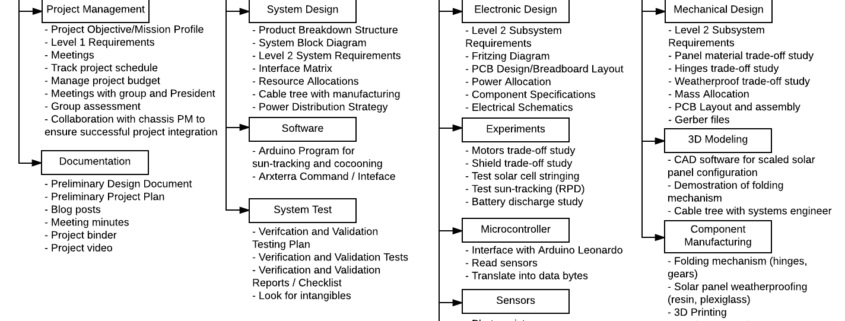
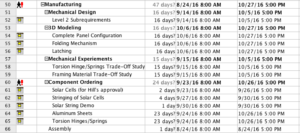
The Work Breakdown Structure shown in Figure 1 demonstrates the work needed to complete the solar panel component of the Pathfinder project. The work branches into the four divisions (including project management) and the work/unique tasks underneath associated with each division.
Project Schedule
By Inna Echual (Project Manager)
Top Level Schedule
Figure 2: Top-Level Schedule
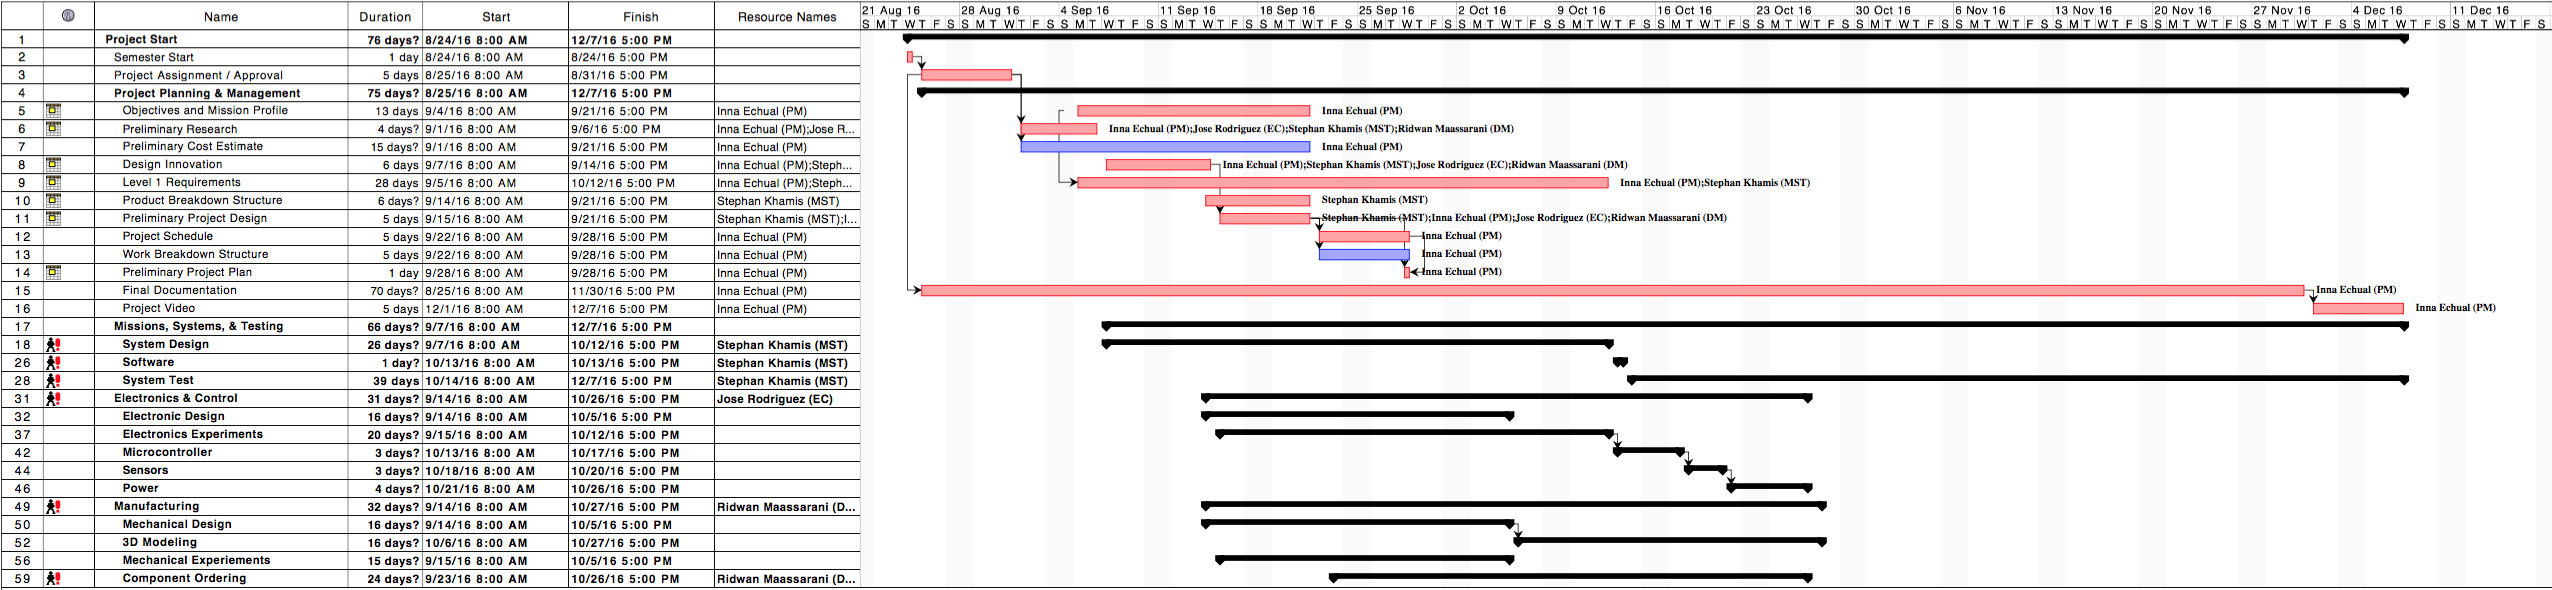
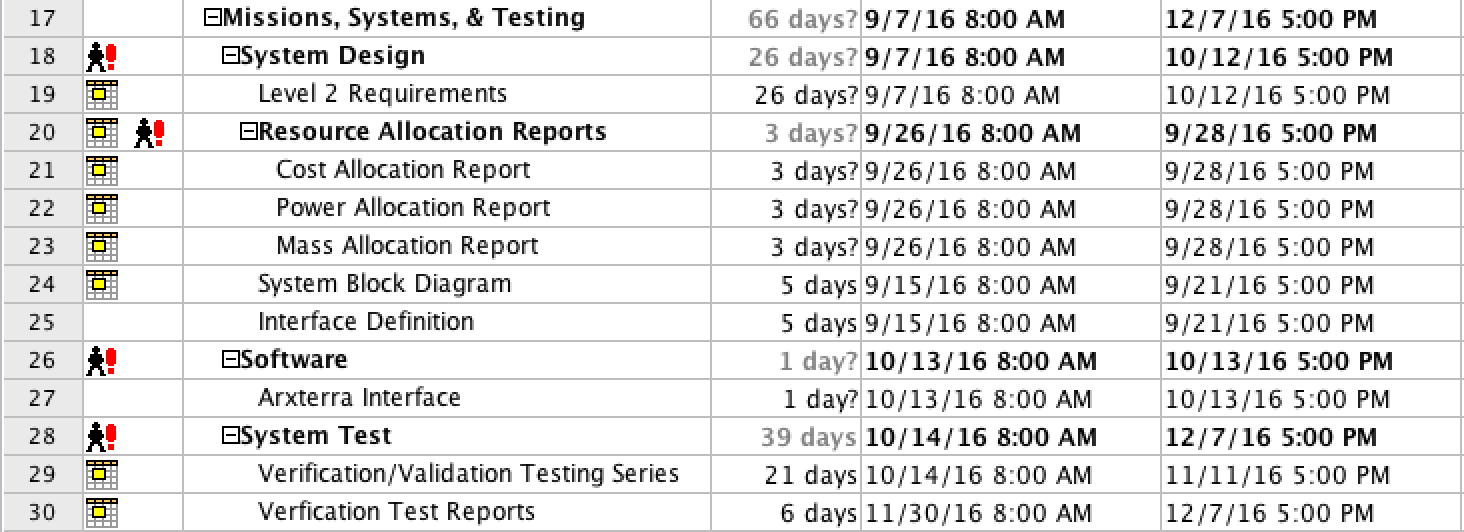
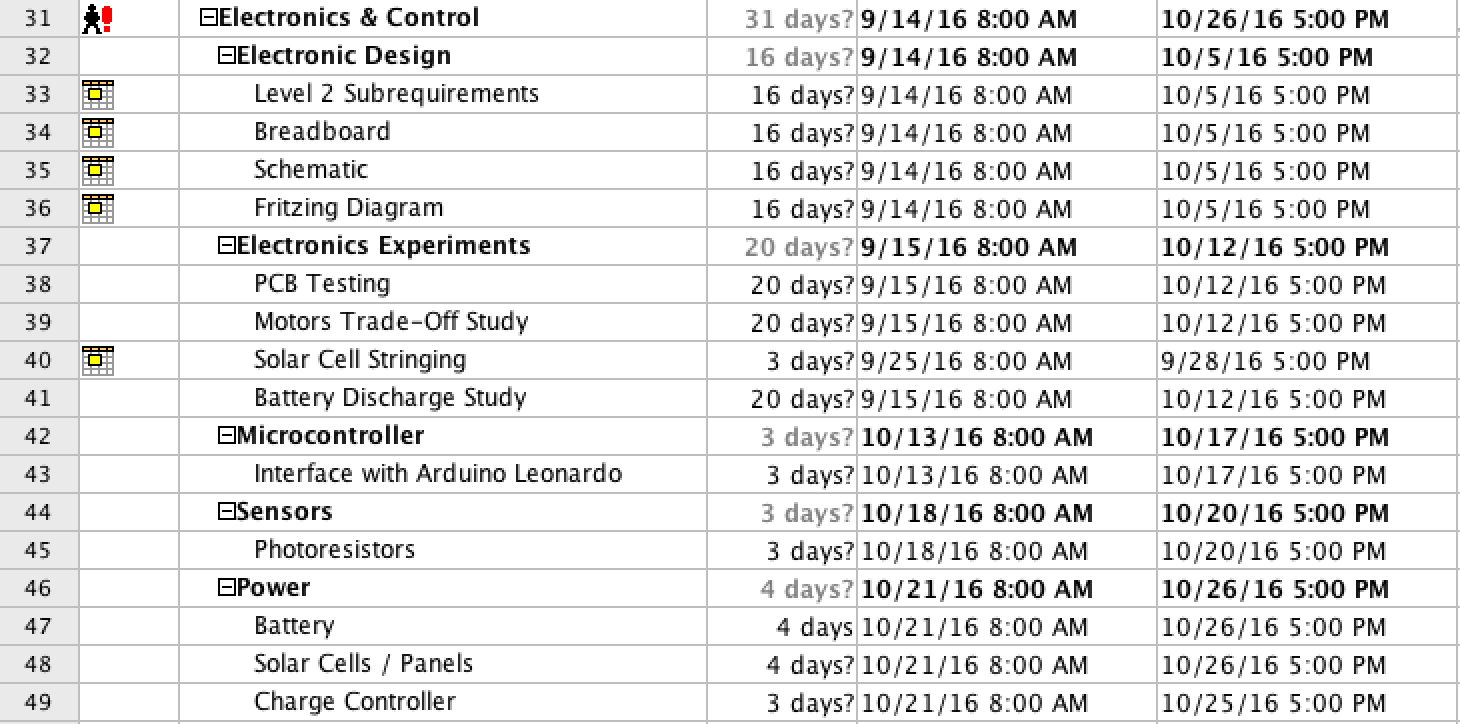
The top-level schedule shown in Figure 2 follows the blocks shown in the work breakdown structure. The major project deadlines are shown under the tasks of the project manager while each division’s individual tasks are nested under their respective division.
Currently, the tasks related to completing the folding mechanism (research, trade-off studies, 3D-Modeling, component specification and ordering, etc.) has the longest completion date and is our current critical path. We don’t have a solid choice for the folding mechanism yet so we still have to do further research and more studies to establish a design in order for our design to move forward.
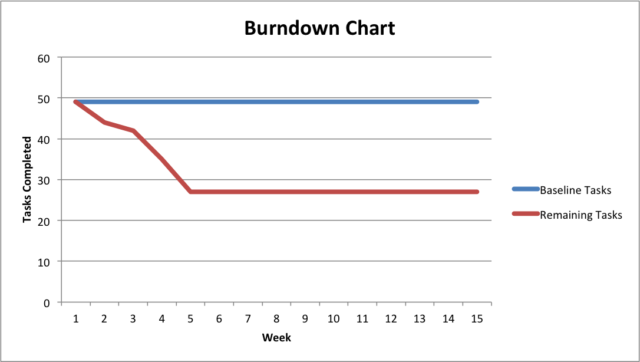
The project Burn Down Chart in Figure 6 demonstrates the work completed so far compared to the total amount of tasks expected to complete the project. The group has completed approximately 30 of the total tasks scheduled for the project. Currently, we are still trying to solidify a design for the folding mechanism so we may fall behind in the upcoming weeks due to research and trade-off studies.
System Resource Allocation Reports
By Stephan Khamis (Mission, Systems, and Testing)
Cost Allocation
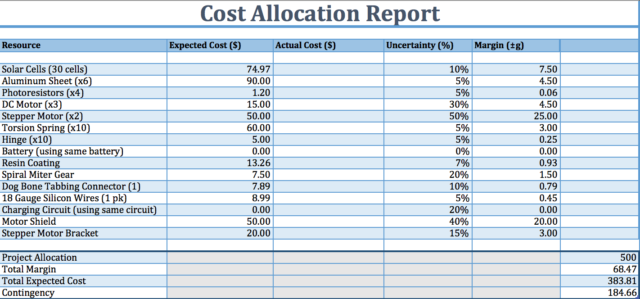
Figure 7: Cost Allocation
Our budget that we have set for ourselves is to keep the project under 500 dollars. All of the expected prices listed in Figure 7 are rough approximations or the average price for that type of component as, for instance, we have yet to define the specifications of the stepper motor will be using so its cost is yet to be defined but we have an approximation of its price. We are reusing some of the parts that were on the previous pathfinder, such as the battery and the charging circuit for the battery. Our total expected cost is $383.81 and we have a contingency of $184.66 dollars. We have allowed ourselves a margin of about $70.
Power Allocation
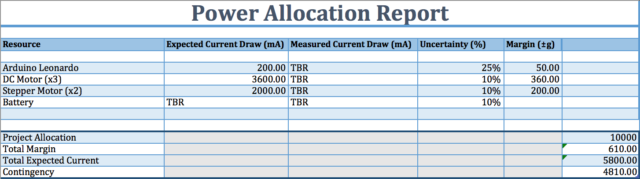
Figure 8: Power Allocation
The expected power allocations are based on the components we expect to be using. We have not specified our motors yet but we have a range of the current draw based on the models we are leaning towards. Battery specifications were to be provided by the chassis group but they have yet to provide us with their experimental data.
Mass Allocation
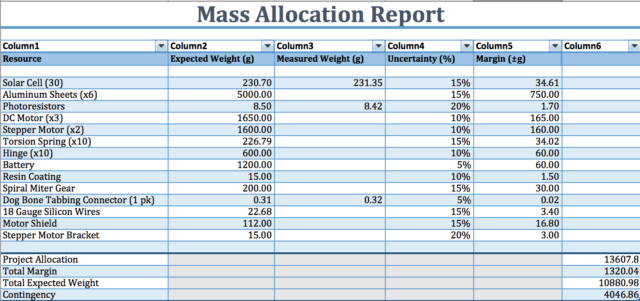
Figure 9: Mass Allocation
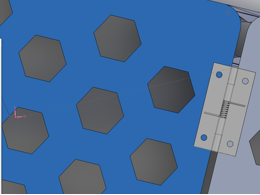
The mass report in Figure 9 are rough approximations of the mass of each component we expect to be using. We have yet to define specifically the DC motors and stepper motors we will be using so their mass is yet to be determined but we have a general idea. The aluminum sheets will have a honeycomb cutout structure to reduce its mass.
Project Cost Estimate
By Inna Echual (Project Manager)
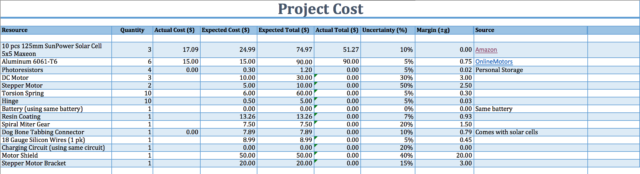
Figure 10: Project Cost Estimate
From the Cost Allocation Report in Figure 7, the overall projected costs are currently estimated to be $383.81. This price will be subjected to change as the project continues and is by no means a representation of a final product. However, we have already selected the type of solar cells we will be using—which are monocrystalline solar cells that already come with the tabbing connectors, ultimately reducing the cost of the overall project. However, the motors and springs have yet to be defined, which I expect will affect our total cost significantly.